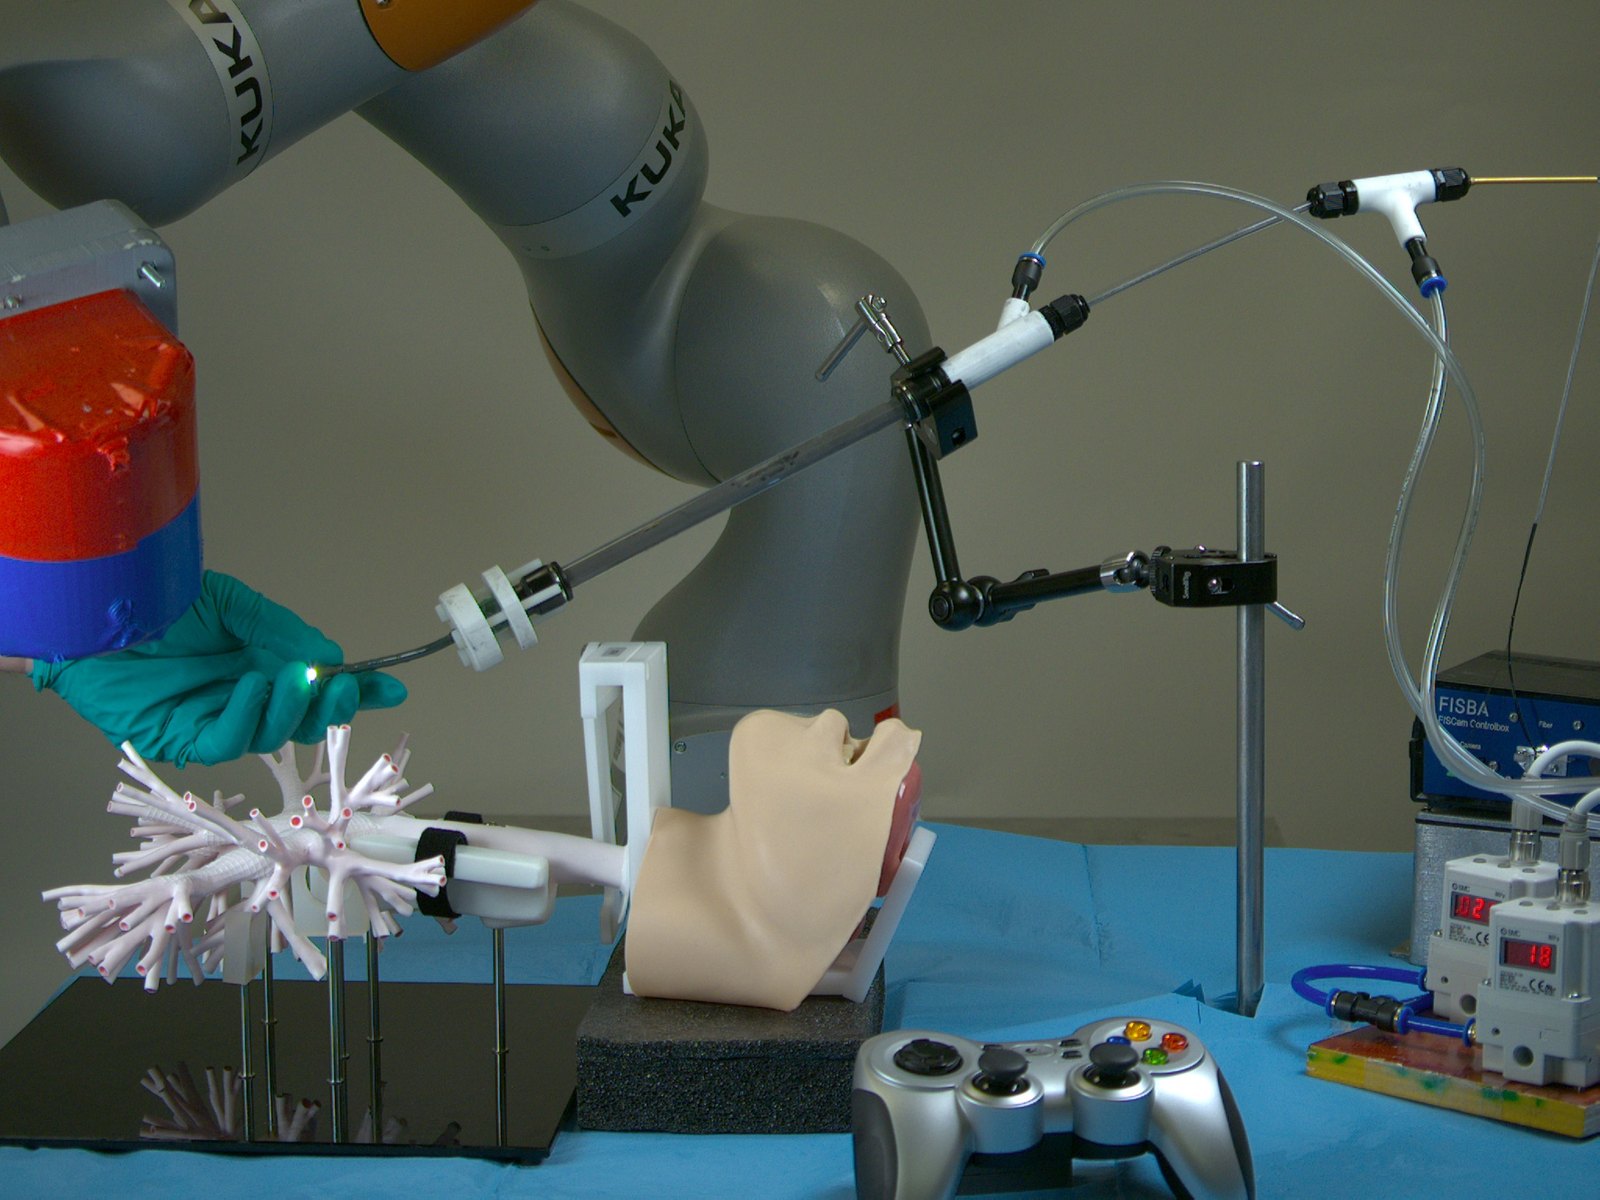
My work runs from materials and fabrication through to programming and non-linear control. The aim is surgery that is more precise, with less trauma for the patient and a shorter recovery.
It depends on close collaboration between engineering, medicine and data science.
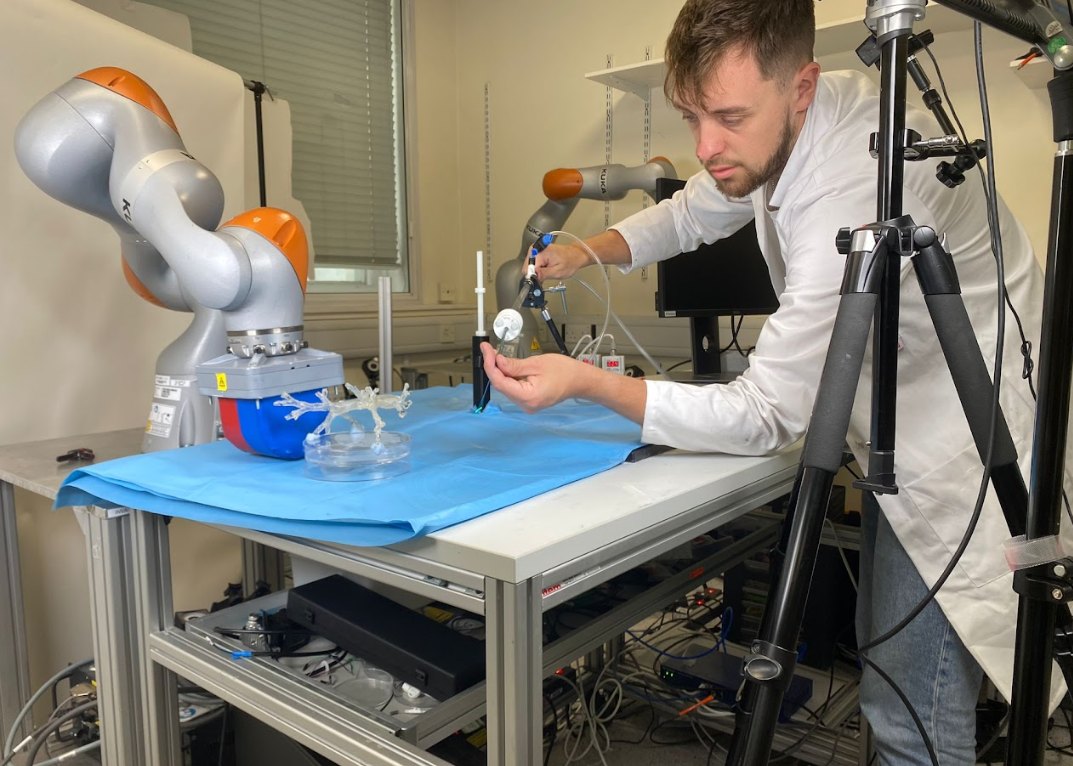
Manufacturing and fabrication
Designing new robots, including miniaturised magnetic vine robots, through careful material selection and novel fabrication processes.
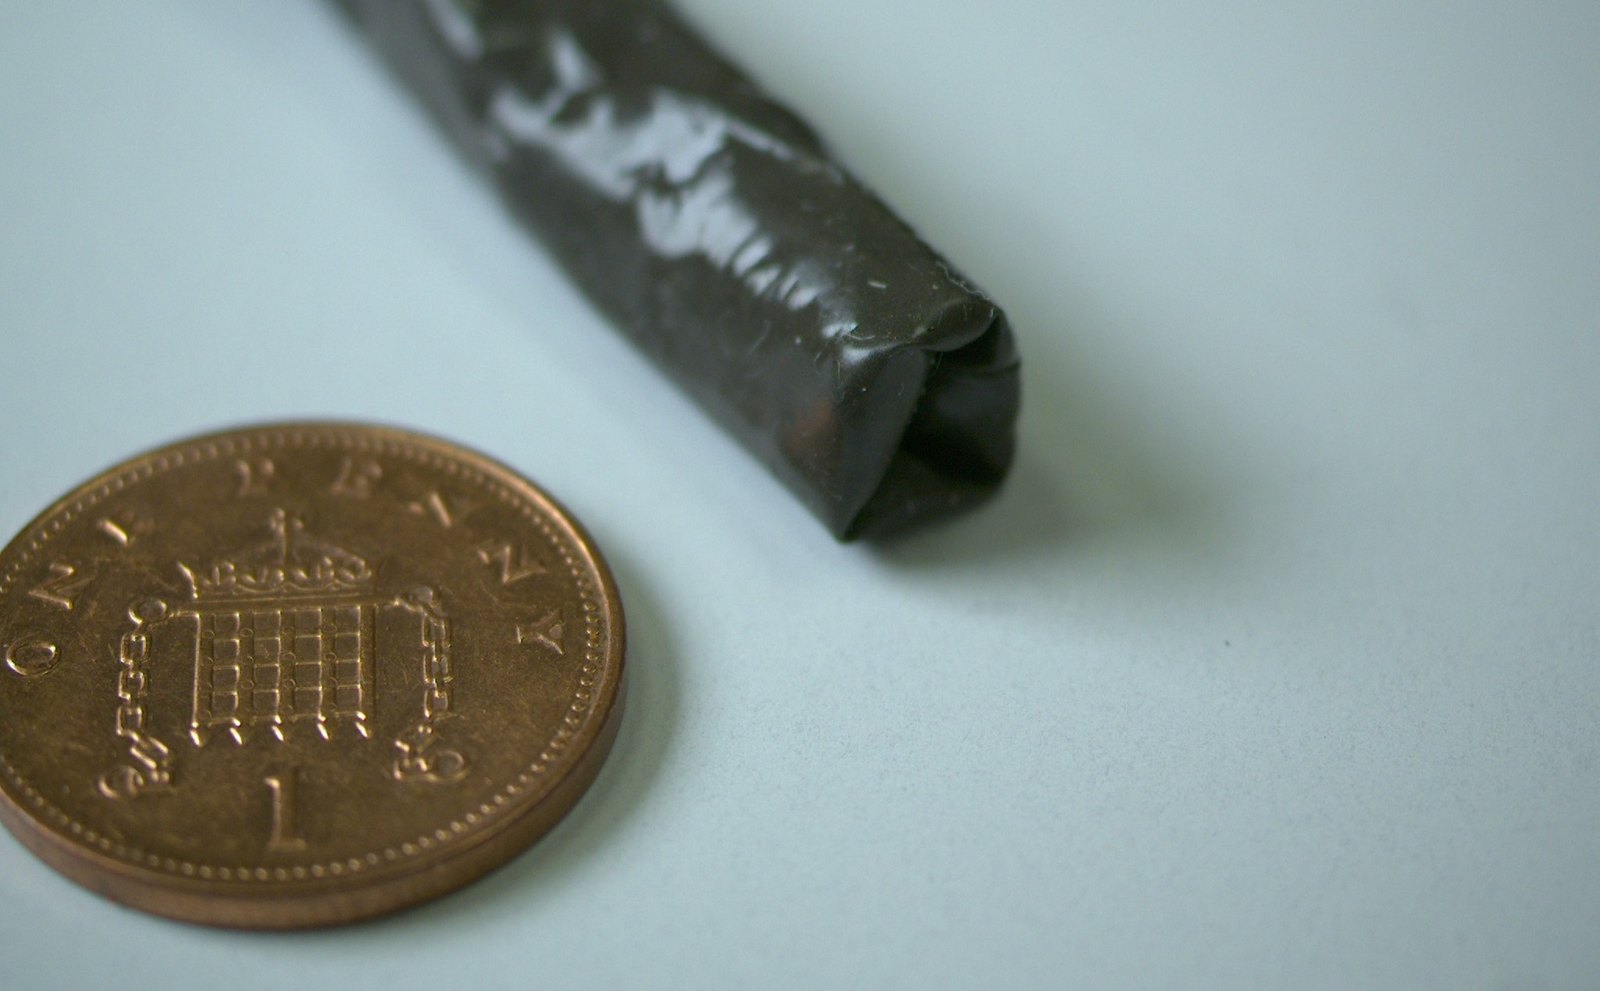
Modelling and simulation
Developing free, open-source simulation software that helps design robots, tune their parameters and predict how they will behave.
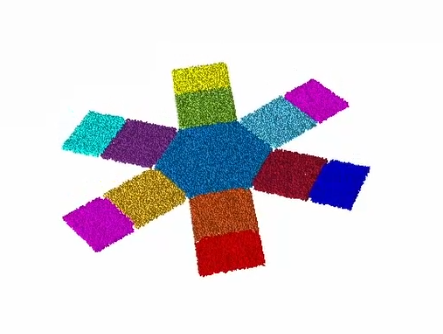
Minimally invasive surgery
Applications in endoluminal navigation: reducing the forces on tissue, reaching deep into the anatomy, and carrying out tasks such as biopsy or drug delivery.