MAGNIS
Magnetically Guided Neural Interface System. A £500,000 opportunity seed funded by ARIA. It applies techniques from my PhD to navigate the endocisternal spaces of the brain, so that electrodes can be implanted minimally invasively.
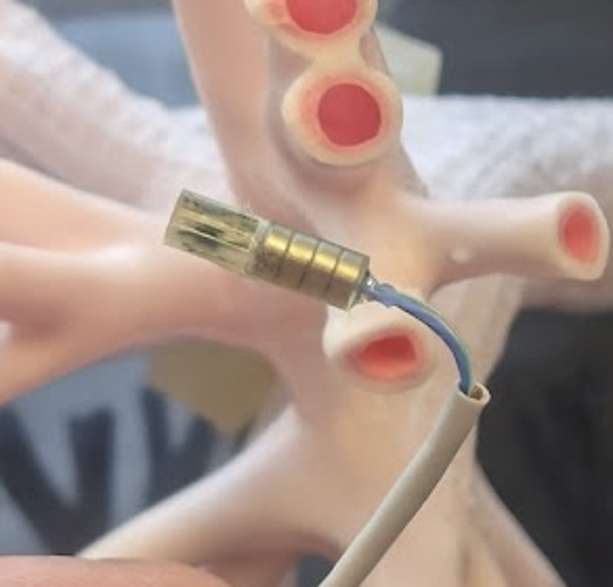
Magnetically Guided Neural Interface System. A £500,000 opportunity seed funded by ARIA. It applies techniques from my PhD to navigate the endocisternal spaces of the brain, so that electrodes can be implanted minimally invasively.
Miniaturising magnetic vine robots so they can navigate highly curved vessels.
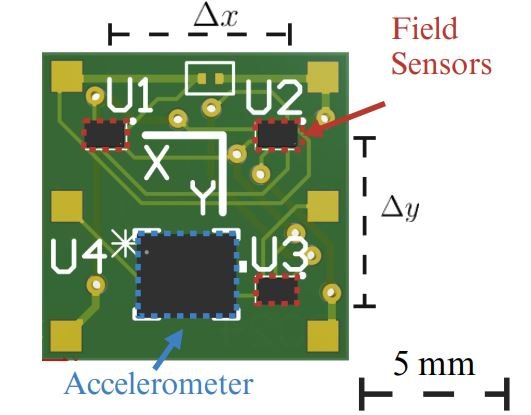
Miniaturised systems that track the full position and orientation of internal magnetic elements, giving closed-loop, intuitive control to the operator.
Fully soft robots that grow under pressure and are steered by magnetic fields through complex, curved anatomy.
A free, open-source simulation framework for magnetic soft robots, for testing ideas, optimising designs and characterisation.
Reducing pesticide use by spraying precisely.
Learning robot gaits in the real world using black-box optimisation.
A microcontroller-based gamepad for teaching embedded systems to undergraduates.